Onat Cakici
001

Rescue Arm

2017
Telescoping / soft gripper · BUILD TIME 3 hrs · Field deployed

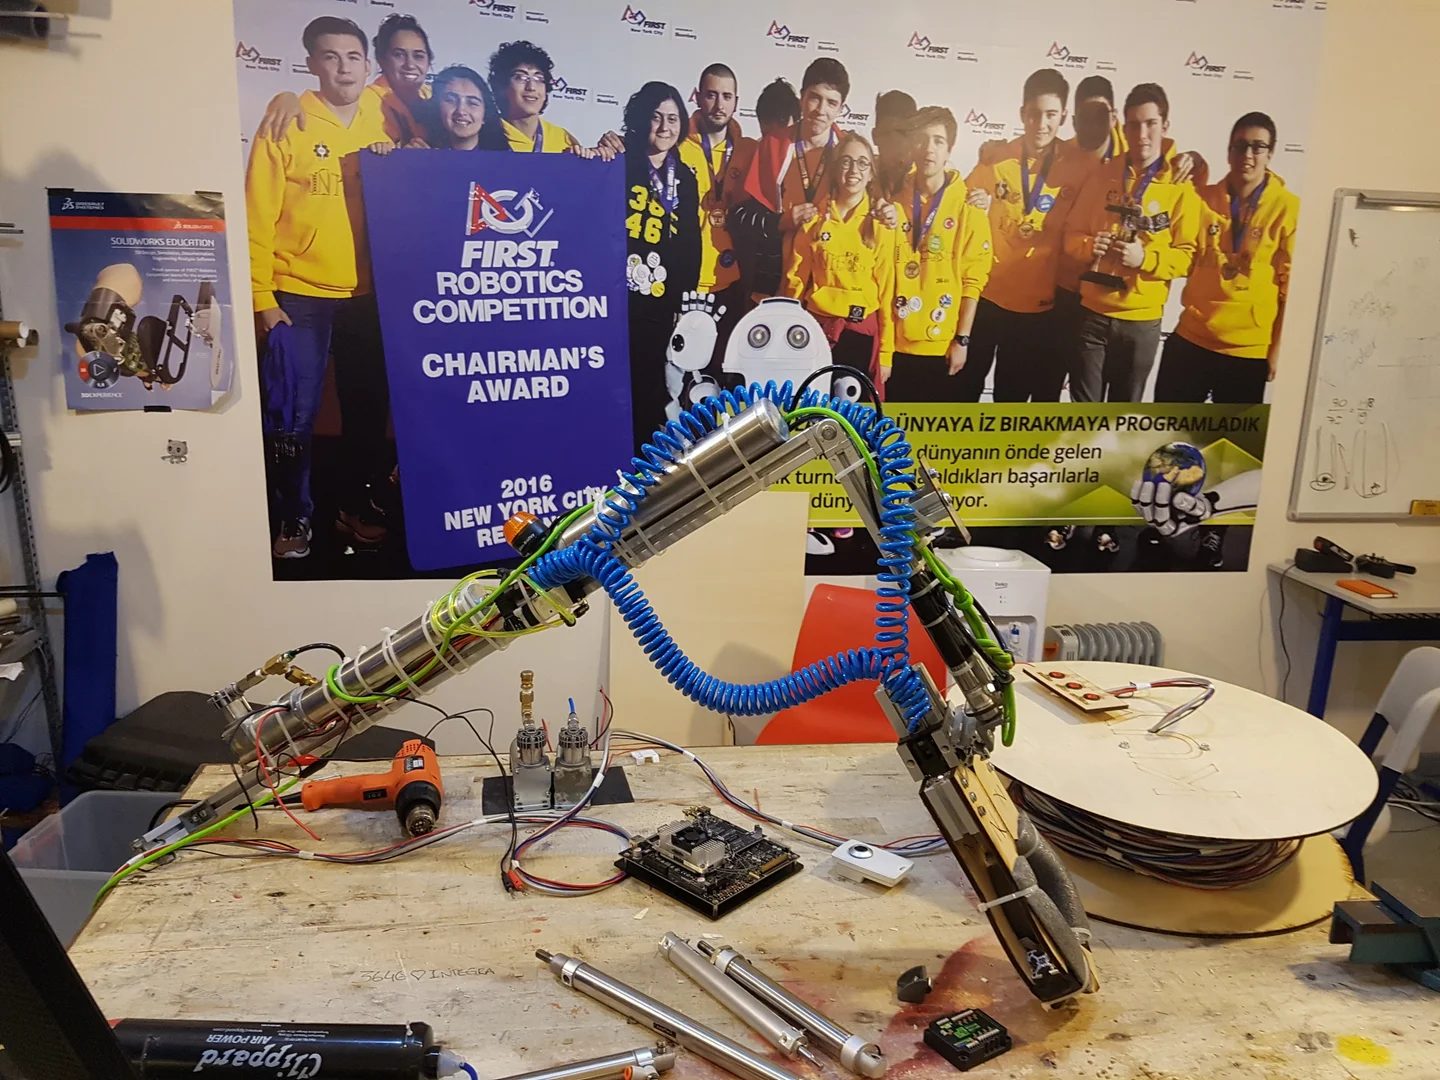
At 16, I helped build a telescoping robotic arm used alongside firefighters to pull a trapped puppy to safety. We heard the news while preparing for a robotics competition and built it within three hours, with a soft gripper for field use.
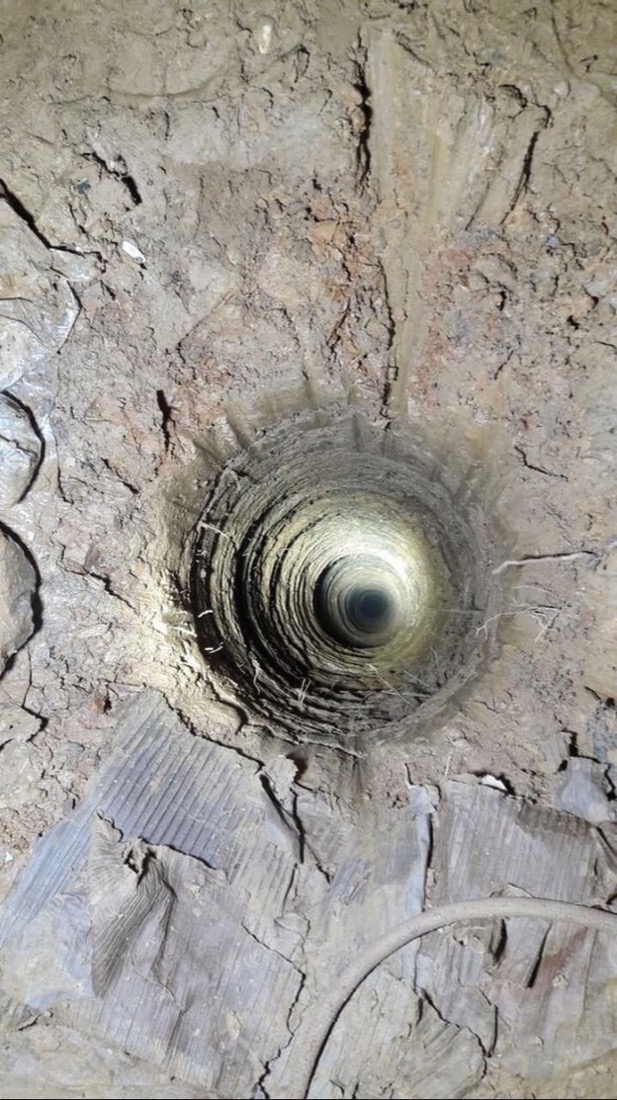
The narrow well shaft where the puppy was trapped, too small for a person to enter
Fig. 01The well: a shaft too narrow for anyone to climb down, opening into a small cave at the bottom where the puppy was trapped. That is what the arm had to reach.
Reuters · 2017

"Rescue of puppy from Istanbul well captivates Turks"

Read the story →
Euronews · 2017

"Robotic arm used to save puppy from well"

Read the story →
New York Post · 2017

"Puppy trapped in well captivates the entire country of Turkey"

Watch the clip →
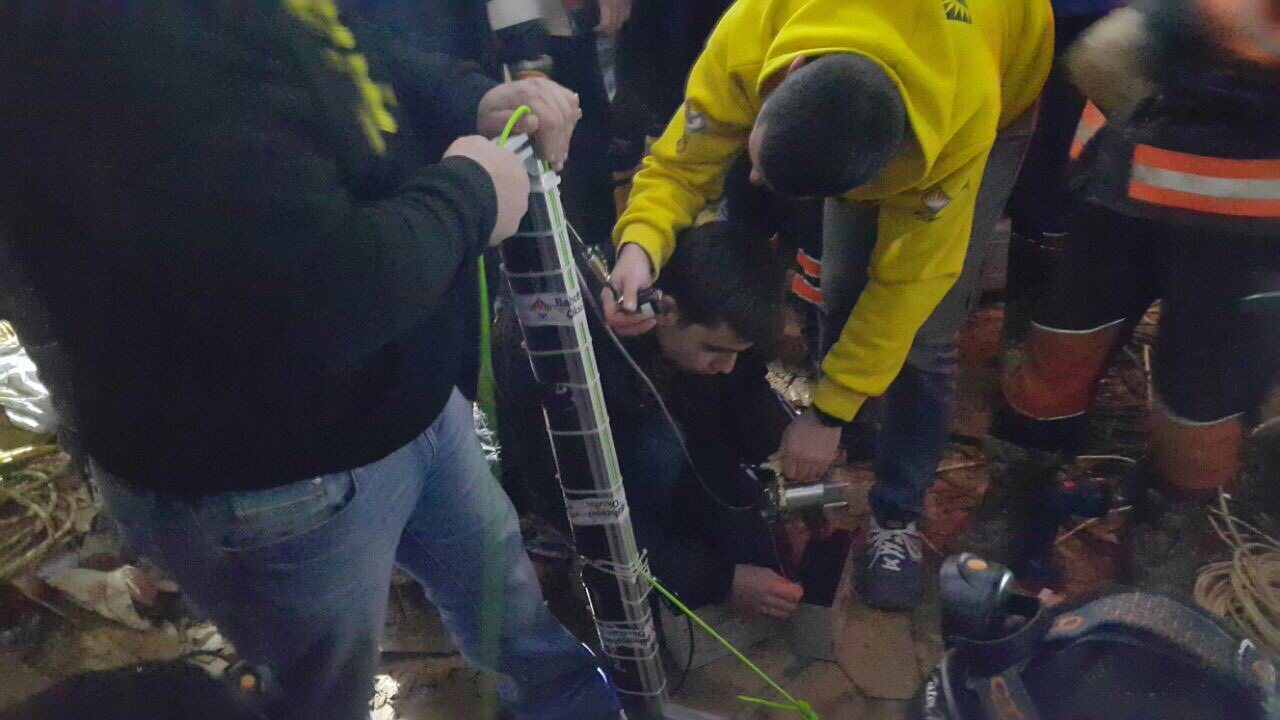
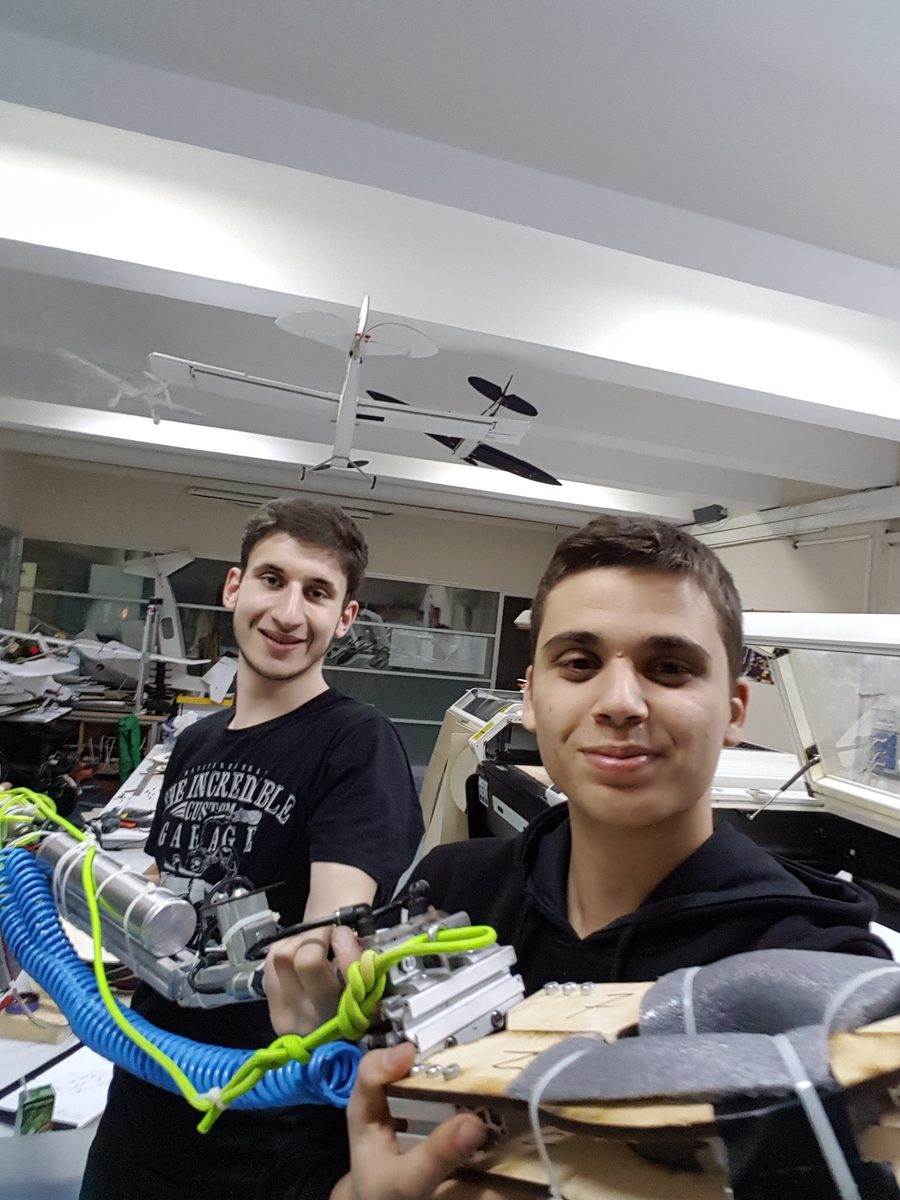
Fig. 02Footage from the Japanese TV program 奇跡体験!アンビリバボー (Kiseki Taiken! Unbelievable), which featured the rescue.
Fig. 03Raw footage from the rescue site: the arm working in the well alongside the rescue teams.
Onat Cakici connecting the battery to charge the pneumatic reservoir for the rescue arm's gripper during the well rescue
Fig. 04That's me connecting the battery to recharge the gripper's pneumatic tanks after a line broke, just before we lowered the arm into the well.
Next: FRC 3646 →

Now building: Porter, an autonomous indoor delivery robot →