005
Porter
2026
Autonomous mobile robot · NAV ROS 2 / LiDAR · Prototype
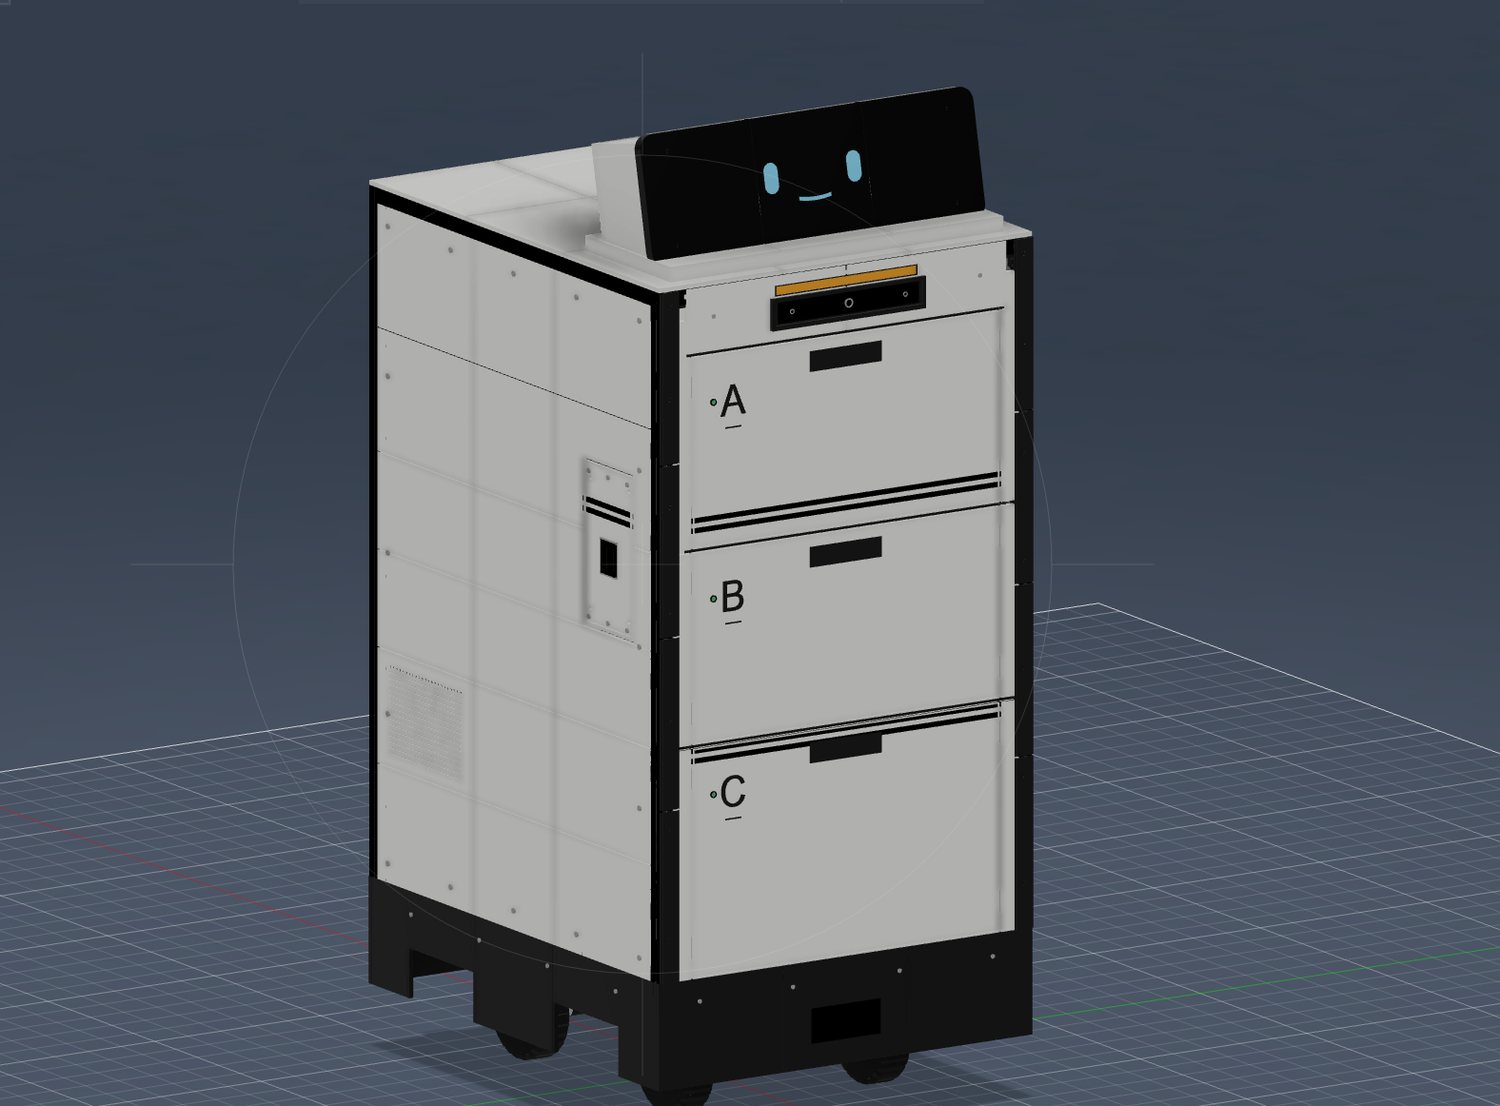
In 2026, I'm building an autonomous indoor delivery robot designed to reduce repetitive delivery work for staff in hotels, residences, and hospitals. Porter combines secure cargo compartments, LiDAR and depth sensing, and ROS 2 navigation for real buildings.