003
Multirotor UAVs
Custom drones · STACK OpenCV / Raspberry Pi
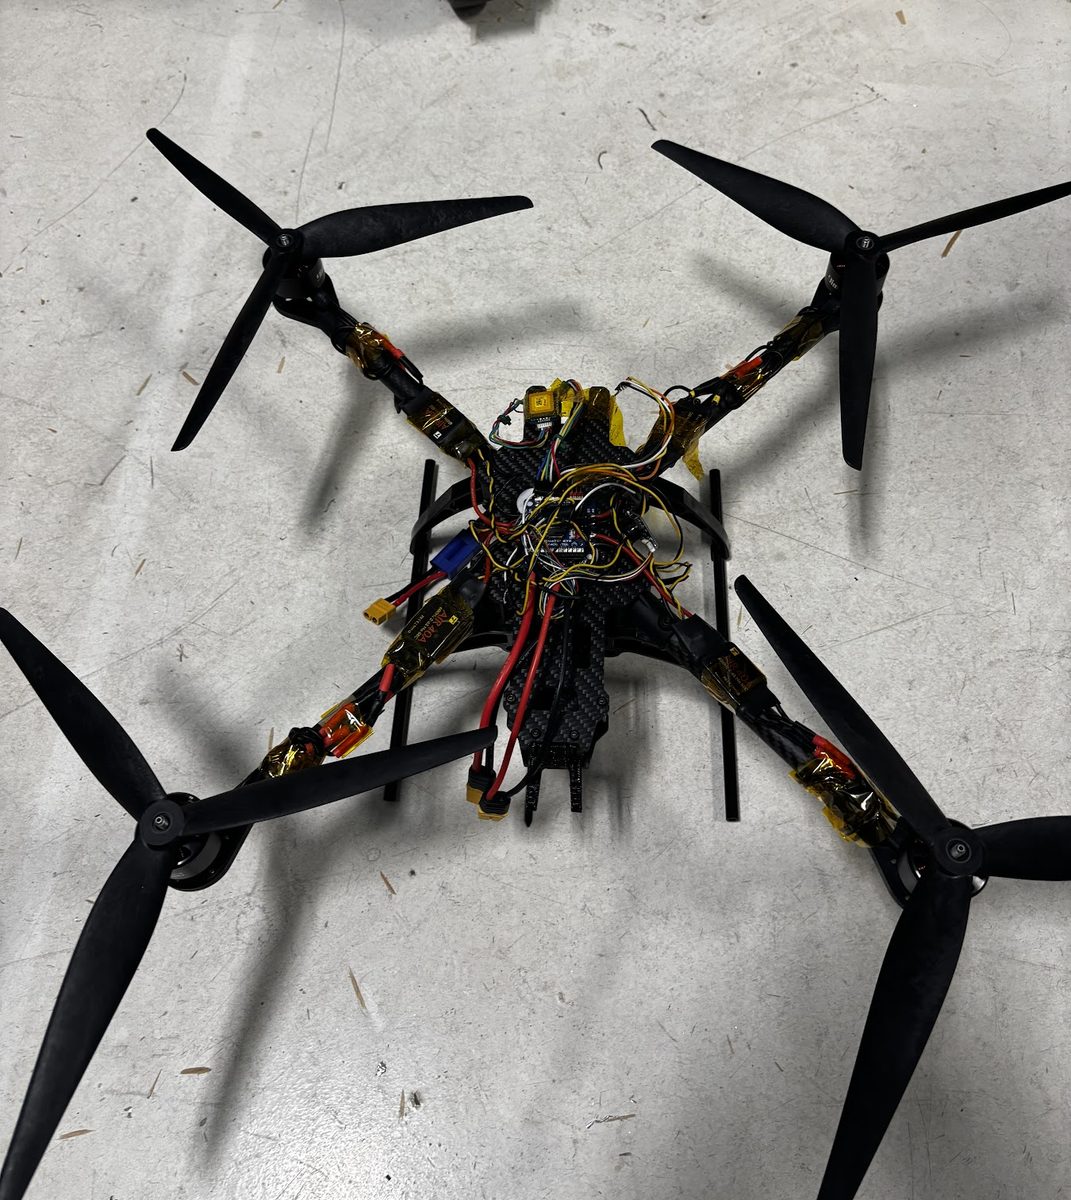
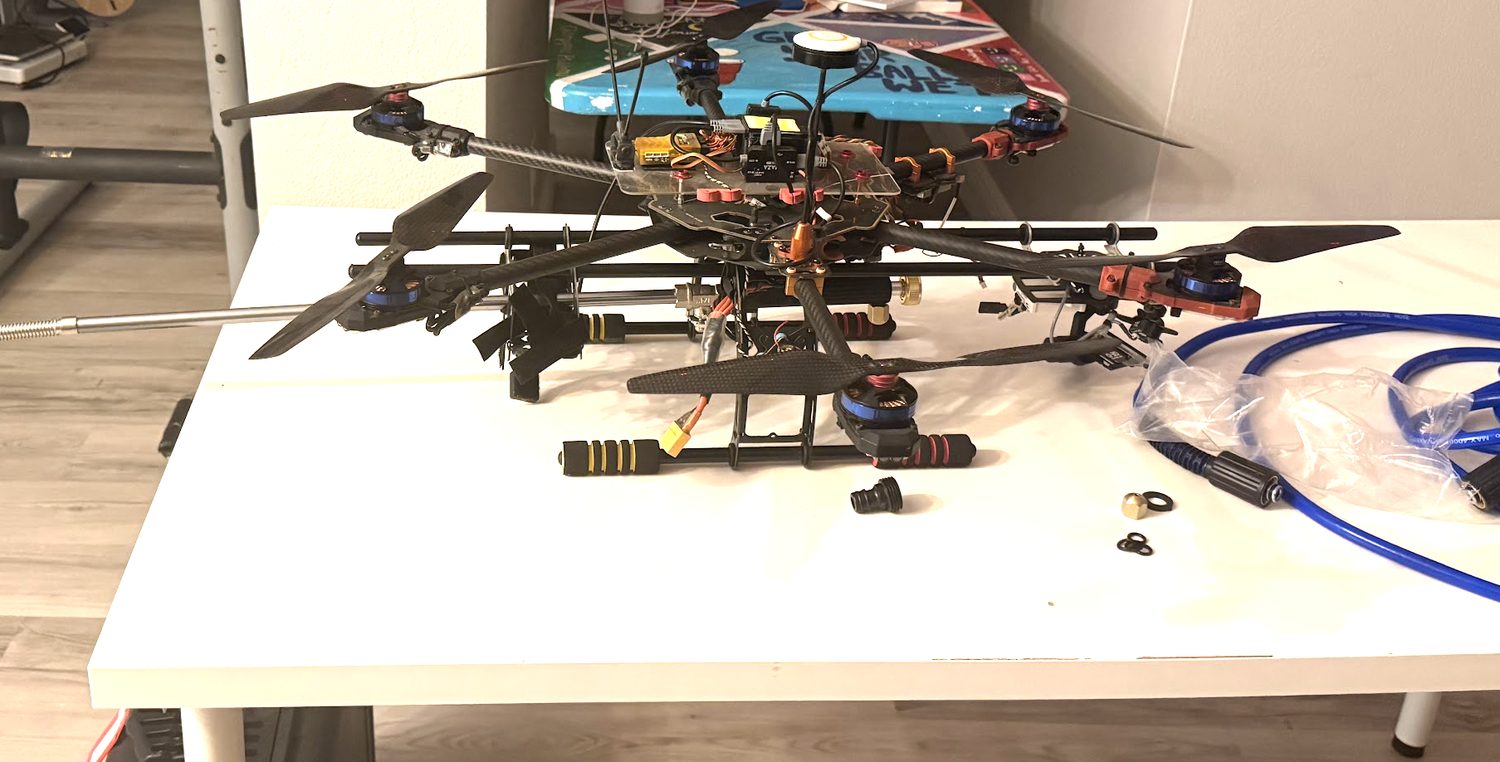
Built, tuned, and flew two custom drones. The first is an autonomous quadcopter for navigation and onboard vision, running OpenCV on a Raspberry Pi. The second is a window-washing drone prototype. Worked across the water pump, flight control, and software.
Now building: Porter, an autonomous indoor delivery robot →